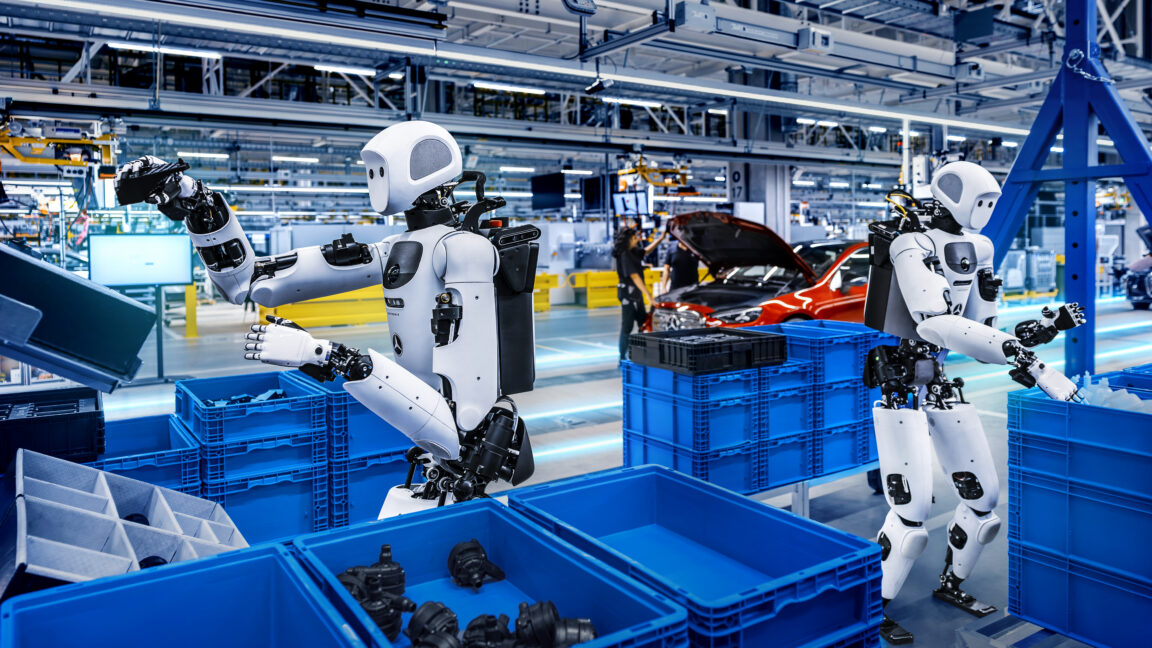
Google DeepMind has introduced the latest iteration of its AI-powered robotic platform, Gemini Robotics 2.5. The company states that this new generation brings robotic intelligence closer to matching human performance in executing complex, real-world tasks. Trials have already been conducted in Mercedes-Benz manufacturing facilities, where the systems successfully completed assigned duties.
As the platform evolves toward a future where robots operate alongside humans, DeepMind is also developing an open-source safety benchmark to ensure secure interactions.
The DeepMind physical AI architecture consists of multiple computational layers situated between user input and robotic execution. One key component is the vision-language model known as Gemini Embodied Reasoning, which interprets instructions and utilizes live video feeds to plan task execution. The second primary element is the vision-language-action (VLA) system, which generates specific robot movements, such as actuating limbs. This VLA component has been upgraded to version 2.5 in the current release.
DeepMind highlights that Gemini Robotics 2.5 shows significant improvements in tasks requiring fine motor skills. The model was tested across more than 200 different activities, ranging from serving food using tongs to operating laboratory pipettes. In a notable demonstration, Apptronik’s Apollo 2 humanoid robot, powered by the new software, successfully tied a bow using its five-fingered hands. This achievement is considered significant because manipulating deformable objects, such as ribbons, remains a major challenge for current robotic systems.



Human-level dexterity sounds like marketing speak. I’d like to see it handling unexpected, messy real-life chaos.
Seeing this in Mercedes factories makes sense. They had the most to lose from failed pilots elsewhere.
Does open-source safety benchmark mean third parties can actually audit the code or just look at test results?
Tying a bow with deformable objects is genuinely impressive. Usually robots struggle so much with soft materials.